Wafer Handling Robot Harness for EFEM and Vacuum Transfer Modules
A wafer handling robot harness for EFEM and vacuum transfer arms, where the loom cycles continuously and runs close to a heated chamber. Fluoropolymer jackets, low outgassing materials and screened legs, built to the motion profile, connector schedule and material rules on your drawing.
Overview
A wafer handling robot harness works in the least forgiving space on the tool. The arm cycles continuously, the end effector passes close to a heated process chamber, and the whole loom sits inside an enclosure where one outgassed contaminant settling on a wafer can scrap a batch. That combination rules out most of what a general purpose industrial loom is made of. We build these assemblies to the motion profile, the connector schedule and the material rules your process engineers have already written down, and we treat every non-metallic component, from the jacket to the lacing tape, as part of the contamination budget rather than as packaging.
Key Specifications
| Build Type | Build to drawing or build to sample |
|---|---|
| Jacket Materials | FEP, PFA or ETFE; no PVC anywhere in the loom |
| Conductor | Silver-plated copper for high temperature and signal legs |
| Outgassing | Low outgassing materials, screened per ASTM E595 when specified |
| Screening | Foil plus braid double screen, drain termination per drawing |
| Static Control | Antistatic or carbon-loaded jacket option |
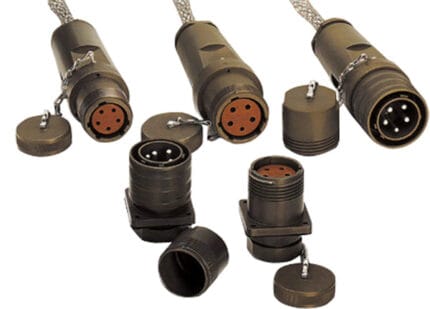
| Terminations | MIL-DTL-26482 style circular, D-Sub, or customer specified |
| Testing | Continuity, dielectric withstand, flex check to your motion profile |
A specification written as a list of material names is weaker than one written as a list of failure modes. On a transfer arm the fault is mechanical long before it is electrical: the conductor work-hardens at one bend point, the jacket cracks there, the screen opens, and only then does the signal go intermittent. That is the order we design against.
| Stress on the loom | What fails first | What the build does about it |
|---|---|---|
| Continuous arm cycling | Strands work-harden at the same bend point and break one at a time | Fine-strand conductor, bend radius stated on the drawing, strain relief at every cable exit |
| Heat near the process chamber | Jacket stiffens and cracks; softened compounds release vapor | Fluoropolymer jacket on the hot end, capability taken from the data sheet of the material you nominate |
| Vacuum and load lock | Plasticizer and adhesive vapor condenses on cold surfaces | Every non-metallic part screened to the same requirement, not only the jacket |
| Charge build-up on moving parts | Attracted particles and discharge events near the wafer | Antistatic or carbon-loaded jacket, drain path defined on the drawing |
| Wipe-down and chemical cleaning | Markers smear, labels lift, lacing absorbs fluid | Marker sleeves, labels and lacing chosen under the same rule as the jacket |
None of these are exotic. They are the five places a returned loom is actually damaged, and every one of them is decided before the first crimp is made.
Outgassing is a bill of materials property
Outgassing gets treated as a jacket property and it is not. A fluoropolymer jacket on a loom held together with general purpose lacing tape, a vinyl marker sleeve and a standard potting compound still introduces exactly what the process engineer was trying to keep out. The rule we work to is that every non-metallic part in the assembly, from the insulation to the label stock, is selected against the same screening requirement. Where your program names ASTM E595 as the screening method, we quote to it and pass through the material data we hold from the supplier. What we will not do is print a pass figure we have not measured on the lot we actually used.
The enclosure matters as well. An equipment front end module is a cleanroom volume with a vacuum load lock at one end, and the two halves of a route do not impose the same requirements at all. Tell us where the harness crosses from one zone to the other and we will flag it, because that transition is exactly where a single material decision tends to get applied to both zones by default.
Flex life is a qualification, not a number
Cycle life figures on a supplier data sheet are measured at a stated bend radius, speed and load, and they mean nothing outside those conditions, so we do not quote one. Instead we take the motion profile off your drawing, meaning the travel, the tightest bend radius, the cycle rate and whether the loom is supported or free, build to it, and run the flex check on the finished assembly rather than on a coupon. The result is reported as measured against the profile you gave us. If it comes back short of your target, that is a routing or a material conversation, and it is far cheaper to have it at the prototype stage than after a tool is down.
Selection is a set of trade-offs rather than a search for the best material:
| Material | Where we use it | What you trade away |
|---|---|---|
| FEP | General loom jacket, easy to process and strip | Lower cut-through resistance than PFA |
| PFA | Hot end and the tightest bends on the arm | Higher material cost |
| ETFE | Where abrasion resistance matters more than the top of the temperature range | Stiffer hand, harder to dress in a tight bundle |
| Silver-plated copper | High temperature legs and low level signal circuits | Cost and lead time on fine gauges |
| PVC | Not used anywhere in these builds | Not applicable |
Temperature and chemical capability come from the data sheet of the material you nominate. We do not publish a rating of our own for a compound we did not formulate.
Screening and drain termination
These looms carry encoder feedback, vacuum sensing and motor power in one bundle, so the screen treatment matters as much as the screen. We build a foil plus braid double screen and land the drain exactly where your drawing says, keeping the drain length short. Where a loom carries both a screen per leg and an overall screen, the two termination points are agreed before the build starts, because a screen bonded at both ends is an antenna and the fix is a decision rather than a material.
Terminations and replacement builds
We terminate circular connectors in MIL-DTL-26482 style, D-Sub, and the connector families already on your equipment schedule, including the ones your tool maker specifies. For a replacement part, send the removed harness. We measure it, photograph it and reproduce it, and we mark on the drawing any place where the original construction is ambiguous, so the call is yours rather than our guess.
Typical applications for this wafer handling robot harness
- End effector and arm looms for atmospheric and vacuum transfer robots
- Load port and load lock power and sense wiring
- Heated chuck and process chamber service looms
- Alignment, mapping and presence sensor wiring inside the front end module
- Replacement looms for installed equipment, reproduced from a sample
What we need from you
- The motion profile, with travel, tightest bend radius and cycle rate.
- The temperature at the hot end, as stated on your drawing.
- The connector schedule, or photographs of the mating faces.
- The signal type per leg, and which legs need their own screen.
- The outgassing or screening requirement your program imposes.
- Quantity, and whether this is a prototype or a production release.
Build, inspection and records
For Wafer Handling Robot builds the line runs to IPC/WHMA-A-620 Class 3 under ISO 9001, terminating 32 to 12 AWG. continuity and pinout are tested on each Wafer unit before it is packed, and seal checking is quoted whenever an ingress rating is on the drawing.
Each harness can carry a serial number with the build record behind it: materials used, crimp tooling, terminations and test results. Photographs of each build stage are available on request, which is useful when the loom goes into a platform that is qualified rather than simply assembled.
Custom builds and ordering
Wafer Handling Robot prototype lots start from 1 to 50 pcs and ship in 3 working days; production requires 500 pcs and runs 14 working days after approval. Tooling not already held adds around 10 working days. Your part number and labeling go on OEM and ODM Wafer shipments, and material certificates and first-article reports can be supplied.
Material declarations against RoHS and REACH are issued per project, alongside the dimensional and electrical reports agreed at quotation; see certifications, compliance and material declarations. Where your drawing names a UL style or another approval, the build follows your drawing and ships with the supporting document rather than a claim of our own. For continuous motion the stranding, lay length and jacket are built to the flex method described under high-flex drag chain harness builds, with the cycle count defined in the test scope. Related reading: our prototyping and FAI process. Tooling for this build is cut in our own tool room and belongs to your program, so a repeat run years later starts from the same tool.
Frequently Asked Questions
<div class="
For a related configuration, see the Surgical Robot Cable Harness with Overmolded Strain Relief and Sealed Joints.
hkw-faq”>
Can you build from the removed harness alone?
Usually. Send the original and we will measure it, photograph it and reproduce it, flagging any point where the original construction is unclear so that you can rule on it.
Do you screen materials for outgassing in house?
We select materials against the screening requirement your program names and pass through the supplier data we hold. Where a test has to be run on the finished lot, we quote it as a line item rather than implying it was done.
What is the prototype quantity?
Wafer Handling Robot prototype lots start from 1 to 50 pcs and ship in 3 working days; production requires 500 pcs and runs 14 working days after approval.
Can the jacket be antistatic?
Yes. Antistatic and carbon-loaded jacket options are available. Tell us which part of the route needs charge control and we will apply it there rather than across the whole loom.
Related assemblies
- Cleanroom Robot Cable Harness for EFEM and Vacuum Transfer Arms
- Custom Industrial Robot Wire Harness
- Surgical Robot Cable Harness with Overmolded Strain Relief and Sealed Joints
- M12 Drag Chain Cable, Continuous Flex Cordset for Cable Carriers
- Encoder Feedback Cable with PUR Jacket for Digital Servo Loops
- Robot Torsion Resistant Cable for Six-Axis Arm Wiring
Full range: Custom Wire Harnesses.
| Build Type | Build to drawing or build to sample |
|---|---|
| Jacket Materials | FEP, PFA or ETFE; no PVC anywhere in the loom |
| Conductor | Silver-plated copper for high temperature and signal legs |
| Outgassing | Low outgassing materials, screened per ASTM E595 when specified |
| Screening | Foil plus braid double screen, drain termination per drawing |
| Static Control | Antistatic or carbon-loaded jacket option |
| Terminations | MIL-DTL-26482 style circular, D-Sub, or customer specified |
| Testing | Continuity, dielectric withstand, flex check to your motion profile |